
1. Service Content
Relying on professional simulation platforms including DELMIA and Process Simulate, we conduct process verification for robot workstations such as spot welding, gluing and roller hemming in a virtual digital environment. Various project risks can be identified in advance to provide reliable digital support for automation scheme review, tooling & fixture design and on-site commissioning.
Reachability and collision check (fundamental)
Verify robot reach and posture at spot welding and gluing positions. Check static and dynamic interferences to avoid collisions, hardware damage and safety risks.
Workstation layout, tooling and welding gun selection verification
Evaluate robot configuration, 7th-axis stroke, safety fence and cable routing. Validate fixture and welding gun parameters against process requirements to reduce rework.
Cycle time calculation, path and spot sequence optimization
Calculate station and line cycle time to identify bottlenecks. Optimize spot order and motion paths to reduce idle travel, balance robot workload and meet capacity targets.
Offline Programming (OLP) to shorten on-site commissioning time
Develop and verify robot programs virtually before export to real robots. Reduce on-site teaching, avoid production disruption and shorten commissioning.
Virtual Commissioning (VC) including PLC signal interlock
Simulate I/O interlock logic for full-station devices to pre-check signal and logic errors. Achieve coordinated verification beyond robot motion simulation.
Scheme review, Simultaneous Engineering (SE) and multi-party collaboration
Offer visual review for teams and customers. Early detect process defects from body CAD and spot layout for timely correction in BIW SE.
Cost reduction, risk control and multi-model flexibility support
Prevent costly fixture and structure modifications after delivery. Quickly assess new model mixed production on existing stations for flexible line planning.
Shorten project launch cycle
Most teaching and process verification are completed virtually before equipment and prototypes arrive. It reduces on-site commissioning work and line downtime, enabling earlier production startup for customers.
Reduce project investment and modification costs
Interferences, reachability and layout defects are detected upfront. Costly on-site rework of welding guns, fixtures, steel structures and cables can be avoided.
Secure cycle time and lock capacity targets
Offline simulation calculates cycle time, identifies bottlenecks and optimizes robot motion. Workstation capacity is validated in advance to prevent post-launch capacity shortage and extra equipment investment.
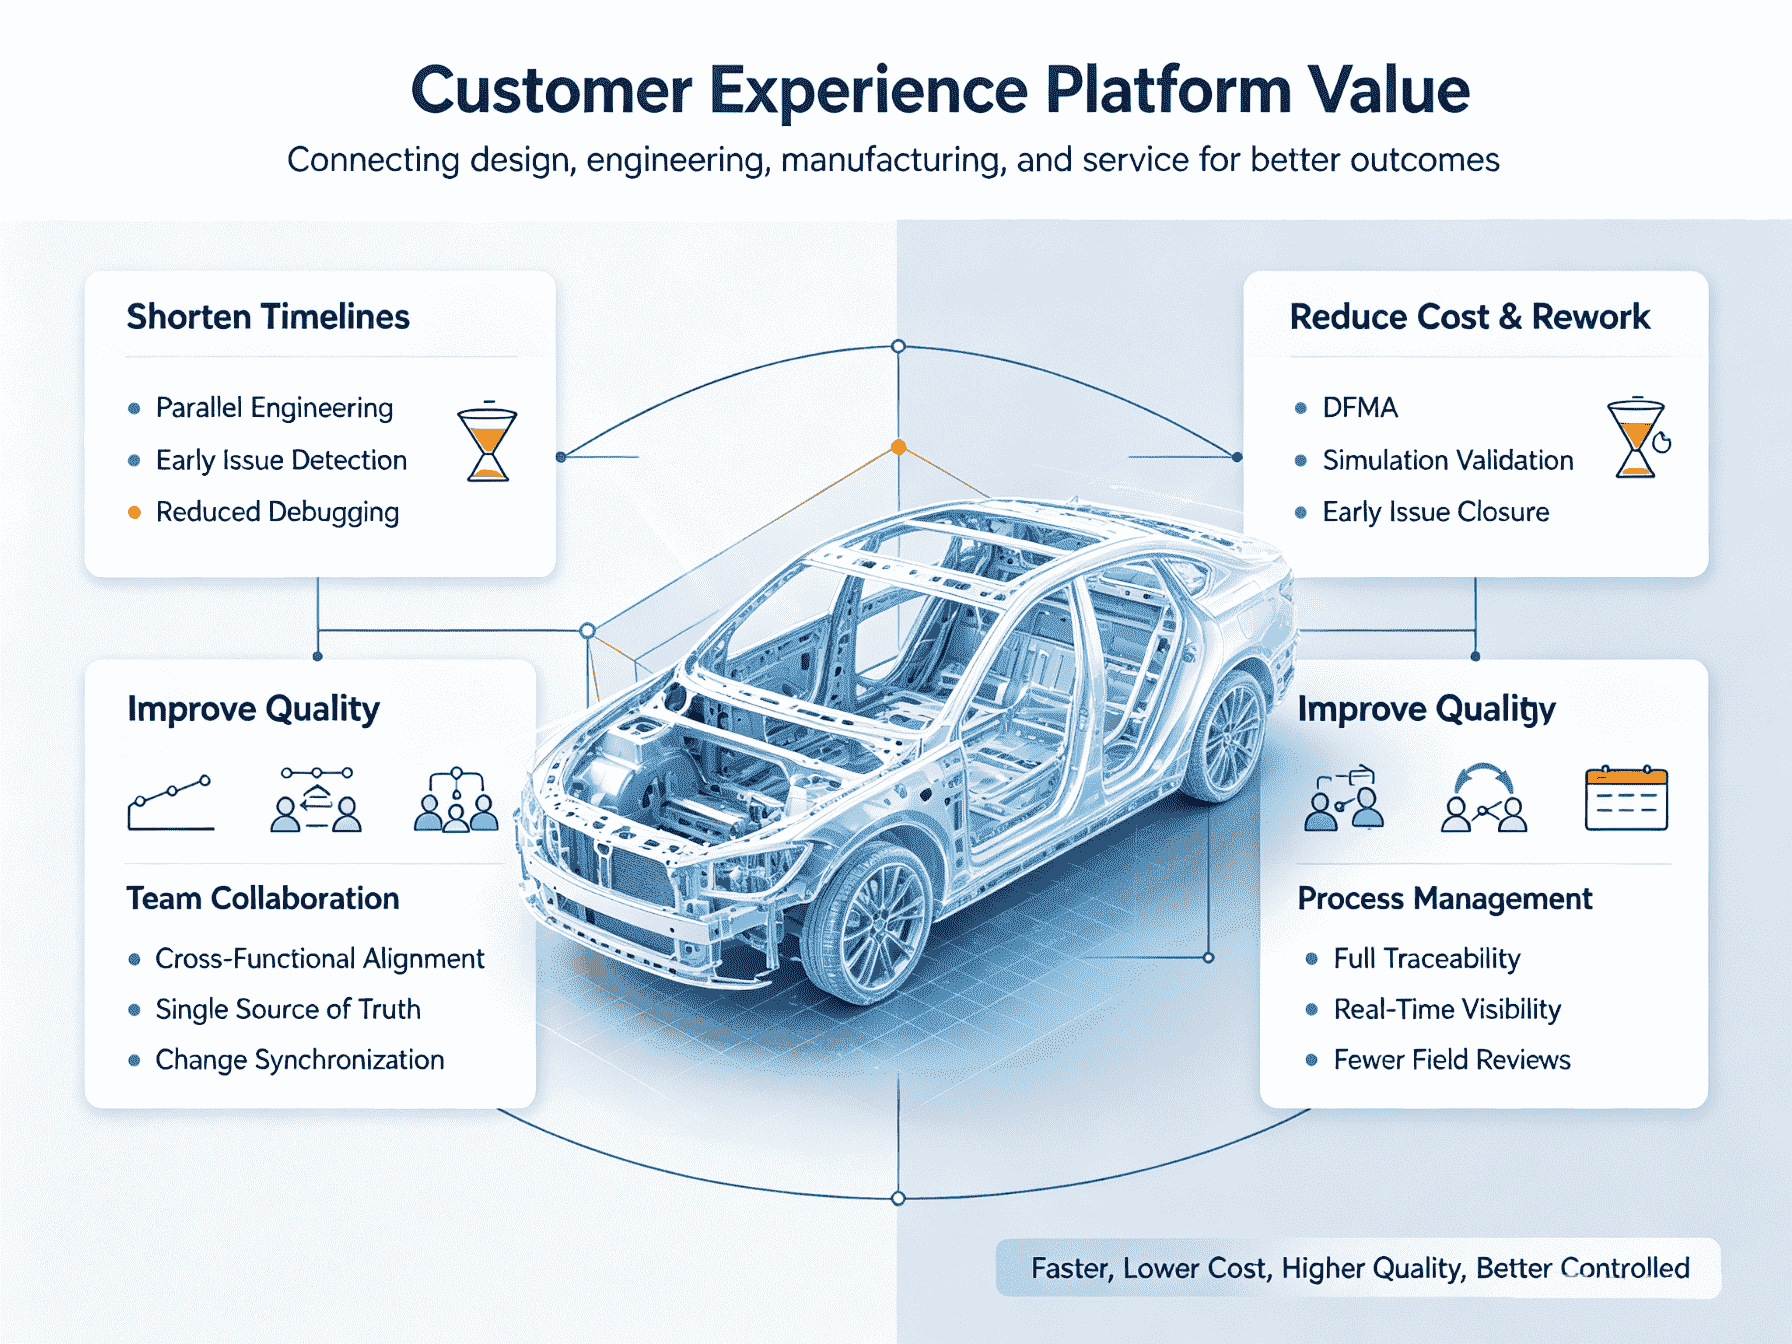
Improve process quality and reduce mass-production issues
Welding and gluing postures are verified upfront to avoid inherent process defects. Stable robot trajectories improve spot consistency and lower production defect rates.
Protect equipment and personal safety
Dynamic collision risks are pre-checked to prevent on-site impacts. It reduces equipment damage, downtime and safety accidents.Support flexible multi-model mixed production and protect customers' long-term investment.New model compatibility on existing lines can be rapidly simulated and assessed. It avoids large-scale line reconstruction, extending line service life and asset utilization.
Reduce reliance on senior engineers for on-site commissioning
Offline programs are directly downloadable to robots; on-site work focuses on verification and fine-tuning. It cuts heavy teaching workload and relieves commissioning staff shortages.Visualized scheme review to reduce communication discrepancies.Simulation animations clearly present workstation motions and workflows. Cross-department reviews enable early consensus, reducing disputes and design changes.
Early Simultaneous Engineering (SE) planning: Workstation layout planning; robot, welding gun and 7th-axis slide selection & verification.
Static and dynamic interference check, collision analysis and optimization proposals.
Spot welding, arc welding and gluing trajectory simulation, posture verification and spot sequence optimization.
Workstation cycle time (CT) analysis and multi-robot load balancing (with OLP template).
Robot OLP programming and post-processed program export.
Simulation animations, demo videos and formal simulation report preparation.
Simulation report (interference analysis and improvement suggestions included)
Installation posture specification for welding guns / arc welding torches
Robot load report
Project Sharing
Spot Welding:
*Single-robot spot welding workstation with positioner *Single-robot spot welding workstation with sliding fixture
*Single-robot spot welding workstation *Dual-robot spot welding workstation (dual robots, two stations)
Arc Welding:
*Single-robot arc welding workstation with 1-axis positioner *Dual-robot arc welding workstation with single-axis positioner *Three-robot arc welding workstation with 1-axis positioner
Offline simulation:
Robotic Welding Production Line:
Connect With Us


Phones: +86 136-0262-0678
Email: dayi-tech@dayi-techequip.com
Whatsapp: +86 136-0262-0678
ESP-B Factory Add: No.10,Yucai Road ,Dalingshan Town, Dongguan City, Guangdong Province, China 523820
Welding Equipment Factory Add: Xiaji 2nd Road, Xintang Town, Zengcheng District, Guangzhou City, Guangdong Province, China 511348
© 2026 Dongguan Dayi Technology Co., Ltd. All rights reserved.
Privacy Policy | Terms and Conditions